2.3Types and General Information about I/O Signals
This section describes the I/O signals for the Robot Controller.
The I/O signals are grouped into user I/O signals and system I/O signals.
User I/O signals are compatible with conventional signals, including the pin pattern, in compatible mode. Note that the connector pin meanings are different between standard mode and compatible mode. Some of the signal lines used for user I/O in compatible mode are used for system input in standard mode.
Additionally, part of the signal lines used for system I/O in compatible mode is used for command execution I/O signals in standard mode.
2.3.1 Standard Mode
| In standard mode, 30 input points for command execution are used to direct | ||
| program start and other instructions as I/O commands. | ||
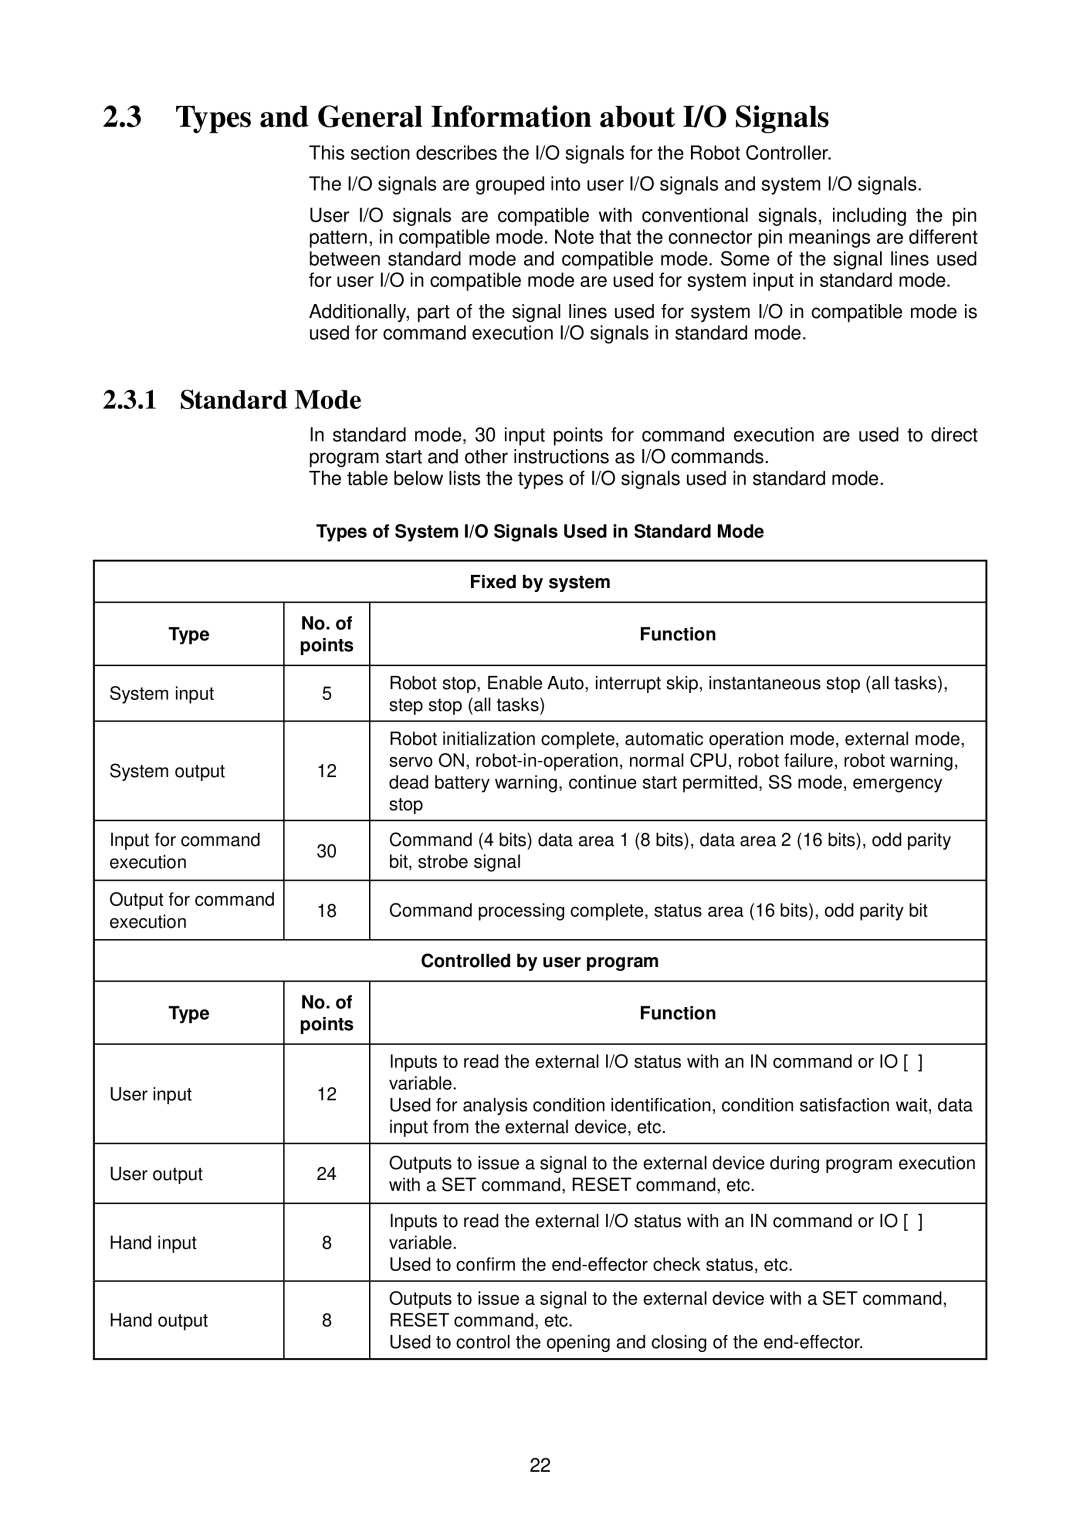
| The table below lists the types of I/O signals used in standard mode. | ||
| Types of System I/O Signals Used in Standard Mode | ||
|
|
| |
|
| Fixed by system | |
|
|
| |
Type | No. of | Function | |
points | |||
|
| ||
|
|
| |
System input | 5 | Robot stop, Enable Auto, interrupt skip, instantaneous stop (all tasks), | |
step stop (all tasks) | |||
|
| ||
|
|
| |
|
| Robot initialization complete, automatic operation mode, external mode, | |
System output | 12 | servo ON, | |
dead battery warning, continue start permitted, SS mode, emergency | |||
|
| ||
|
| stop | |
|
|
| |
Input for command | 30 | Command (4 bits) data area 1 (8 bits), data area 2 (16 bits), odd parity | |
execution | bit, strobe signal | ||
| |||
|
|
| |
Output for command | 18 | Command processing complete, status area (16 bits), odd parity bit | |
execution | |||
|
| ||
|
|
| |
|
| Controlled by user program | |
|
|
| |
Type | No. of | Function | |
points | |||
|
| ||
|
|
| |
|
| Inputs to read the external I/O status with an IN command or IO [ ] | |
User input | 12 | variable. | |
Used for analysis condition identification, condition satisfaction wait, data | |||
|
| ||
|
| input from the external device, etc. | |
|
|
| |
User output | 24 | Outputs to issue a signal to the external device during program execution | |
with a SET command, RESET command, etc. | |||
|
| ||
|
|
| |
|
| Inputs to read the external I/O status with an IN command or IO [ ] | |
Hand input | 8 | variable. | |
|
| Used to confirm the | |
|
|
| |
Hand output | 8 | Outputs to issue a signal to the external device with a SET command, | |
RESET command, etc. | |||
|
| Used to control the opening and closing of the | |
|
|
| |
22