13-3 Troubleshooting for Specific Symptom
13
TROUBLESHOOTING
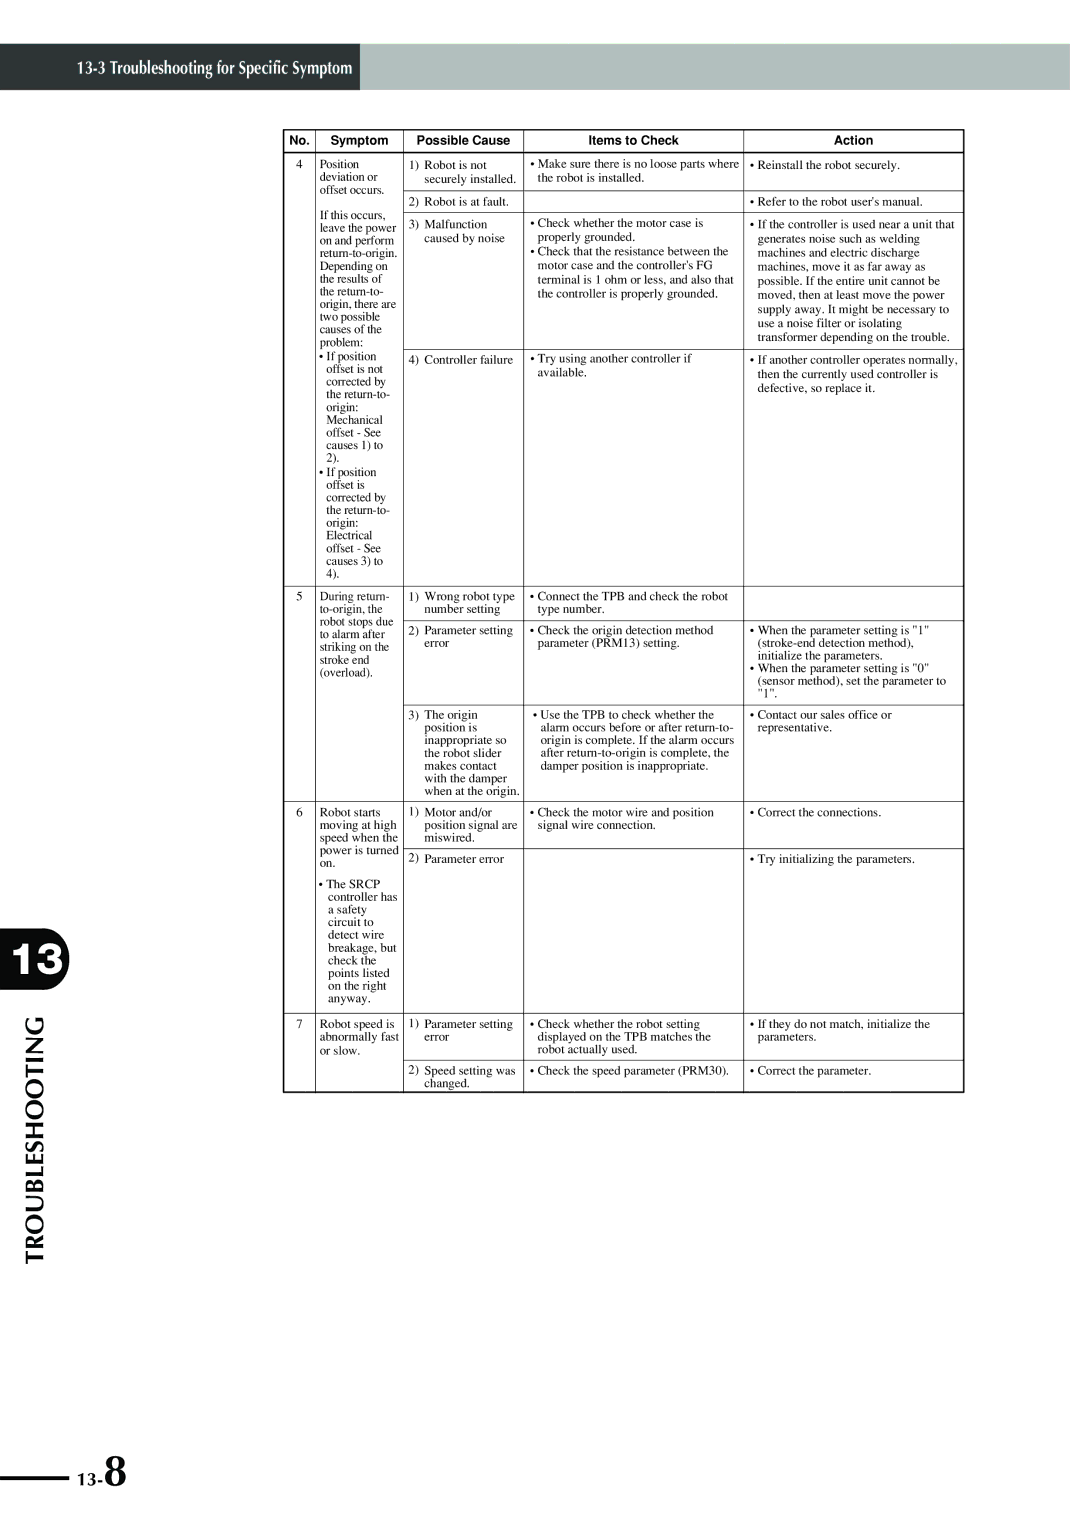
No. | Symptom | Possible Cause | Items to Check | Action |
|
|
|
|
|
4 | Position | 1) Robot is not | • Make sure there is no loose parts where | • Reinstall the robot securely. |
| deviation or | securely installed. | the robot is installed. |
|
| offset occurs. |
|
|
|
| 2) Robot is at fault. |
| • Refer to the robot user's manual. | |
| If this occurs, |
| ||
|
|
|
| |
| 3) Malfunction | • Check whether the motor case is | • If the controller is used near a unit that | |
| leave the power | |||
| on and perform | caused by noise | properly grounded. | generates noise such as welding |
|
| • Check that the resistance between the | machines and electric discharge | |
| Depending on |
| motor case and the controller's FG | machines, move it as far away as |
| the results of |
| terminal is 1 ohm or less, and also that | possible. If the entire unit cannot be |
| the |
| the controller is properly grounded. | moved, then at least move the power |
| origin, there are |
|
| supply away. It might be necessary to |
| two possible |
|
| |
|
|
| use a noise filter or isolating | |
| causes of the |
|
| |
|
|
| transformer depending on the trouble. | |
| problem: |
|
| |
|
|
|
| |
| • If position | 4) Controller failure | • Try using another controller if | • If another controller operates normally, |
| offset is not |
| available. | then the currently used controller is |
| corrected by |
| ||
|
|
| defective, so replace it. | |
| the |
|
| |
|
|
|
| |
| origin: |
|
|
|
| Mechanical |
|
|
|
| offset - See |
|
|
|
| causes 1) to |
|
|
|
| 2). |
|
|
|
| • If position |
|
|
|
| offset is |
|
|
|
| corrected by |
|
|
|
| the |
|
|
|
| origin: |
|
|
|
| Electrical |
|
|
|
| offset - See |
|
|
|
| causes 3) to |
|
|
|
| 4). |
|
|
|
|
|
|
|
|
5 | During return- | 1) Wrong robot type | • Connect the TPB and check the robot |
|
| number setting | type number. |
| |
| robot stops due |
|
|
|
| 2) Parameter setting | • Check the origin detection method | • When the parameter setting is "1" | |
| to alarm after | |||
| error | parameter (PRM13) setting. | ||
| striking on the | |||
|
|
| initialize the parameters. | |
| stroke end |
|
| |
|
|
| • When the parameter setting is "0" | |
| (overload). |
|
| |
|
|
| (sensor method), set the parameter to | |
|
|
|
| |
|
|
|
| "1". |
|
|
|
|
|
|
| 3) The origin | • Use the TPB to check whether the | • Contact our sales office or |
|
| position is | alarm occurs before or after | representative. |
|
| inappropriate so | origin is complete. If the alarm occurs |
|
|
| the robot slider | after |
|
|
| makes contact | damper position is inappropriate. |
|
|
| with the damper |
|
|
|
| when at the origin. |
|
|
|
|
|
|
|
6 | Robot starts | 1) Motor and/or | • Check the motor wire and position | • Correct the connections. |
| moving at high | position signal are | signal wire connection. |
|
| speed when the | miswired. |
|
|
| power is turned |
|
|
|
| 2) Parameter error |
| • Try initializing the parameters. | |
| on. |
|
|
|
| • The SRCP |
|
|
|
| controller has |
|
|
|
| a safety |
|
|
|
| circuit to |
|
|
|
| detect wire |
|
|
|
| breakage, but |
|
|
|
| check the |
|
|
|
| points listed |
|
|
|
| on the right |
|
|
|
| anyway. |
|
|
|
|
|
|
|
|
7 | Robot speed is | 1) Parameter setting | • Check whether the robot setting | • If they do not match, initialize the |
| abnormally fast | error | displayed on the TPB matches the | parameters. |
| or slow. |
| robot actually used. |
|
|
|
|
|
|
|
| 2) Speed setting was | • Check the speed parameter (PRM30). | • Correct the parameter. |
|
| changed. |
|
|