11
COMMUNICATION WITH PC
11-3 Communication Command Specifications
On the SRCP controller, a command interface resembling the BASIC programming language is pro- vided as standard, to facilitate easy communication with a PC. Communication commands are di- vided into the following four categories:
1.Robot movements
2.Data handling
3.Utilities
4.Special codes
Format: (except for special codes)
@<operation code> [<operand 1>][,<operand 2>][,<operand 3>]c/r l/f
■Basically, all of the commands begin with the start code '@' (=40H) and end with the code c/r (=0DH) l/f (=0AH). These two codes signal the controller that the statements between them constitute one command line. (The special codes are the only ones that do not require a start or an end code.)
■A communication command is basically composed of an operation code and an operand. De- pending on the command statement, either no operand is used, or up to three operands are used.
Items in [ ] (brackets) can be omitted.
■The character codes used in the SRCP series, are the JIS8 unit system codes (ASCII codes with katakana characters added). Input characters can be upper case or lower case.
■One or more space must be inserted between the operation code and the operand.
■Items with the < > marks should be specified by the user. Check the description of each communication command and enter the appropriate data. (Refer to
■When two or more operands are entered, insert a comma (,) between them.
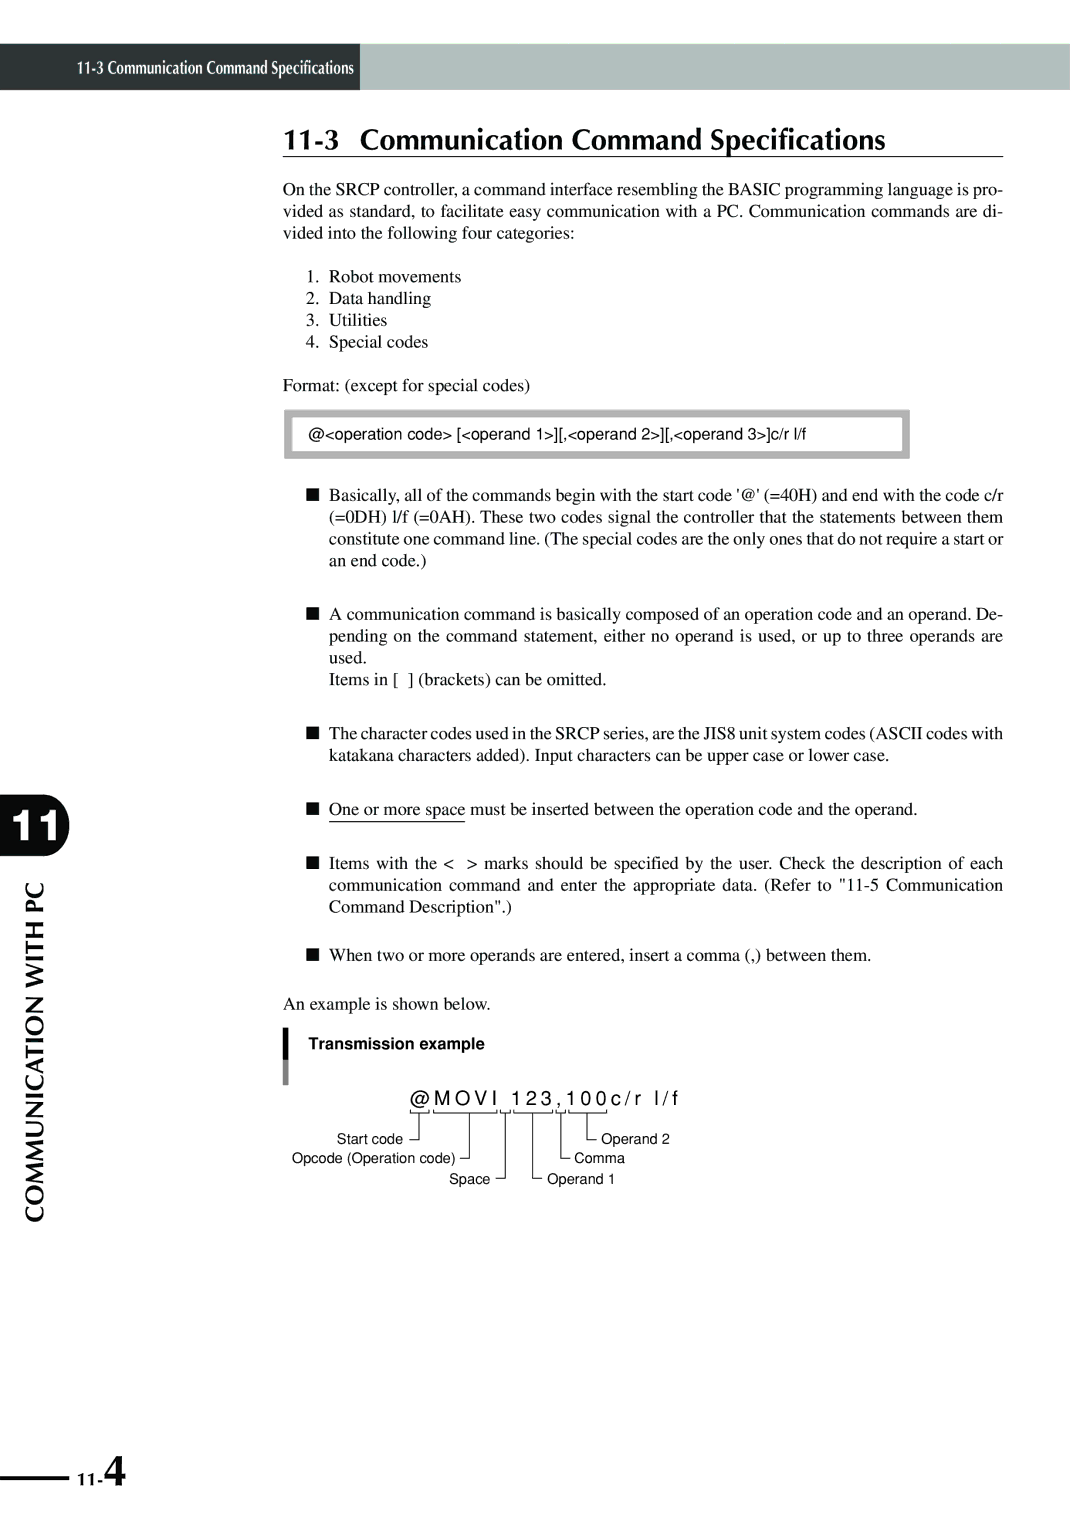
An example is shown below.
Transmission example
@ M O V I 1 2 3 , 1 0 0 c / r l / f
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
|
Start code |
|
|
|
|
|
|
|
|
|
|
|
|
|
| Operand 2 | ||
|
|
|
|
|
|
|
|
|
| ||||||||
Opcode (Operation code) |
|
|
|
|
|
|
|
|
| Comma | |||||||
|
|
|
|
|
|
|
|
| |||||||||
|
|
|
| Space |
|
|
|
| Operand 1 | ||||||||
|
|
|
| ||||||||||||||